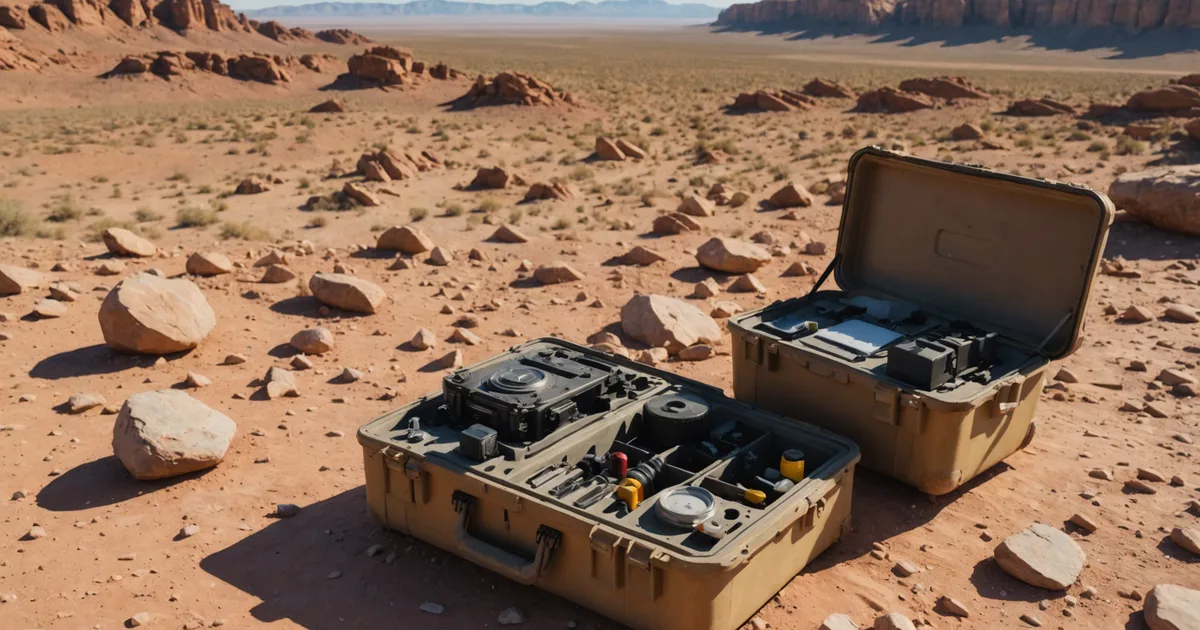
Earlier this year we completed our first structured pilot deployment on an active exploration tenement in a greenstone belt gold corridor in Western Australia. I want to write about what actually happened, not what we expected to happen. There is enough promotional content in the deep-tech hardware space. A more useful contribution is an honest account of where the instrument performed well, where we encountered limitations we hadn't fully anticipated, and what it changed in our thinking about the next phase of development.
The survey context
The tenement covers approximately 14 square kilometres of greenstone belt terrain with known gold mineralisation along a northeast-trending shear zone. The exploration company had existing fluxgate gradiometer data at 50-metre line spacing and several historic drill holes confirming gold and sulphide mineralisation at depths between 80 and 220 metres. They wanted to understand whether finer magnetic gradient detail at 10-metre line spacing would help prioritise drill targets within the known corridor. We agreed to run a comparative traverse across three representative sections with our instrument and their fluxgate system operating on the same lines within the same day.
Signal performance at depth targets
Over the two sections with known shallow mineralisation at 80 to 120 metres depth, the NV-center gradiometer resolved lateral gradient features at a spatial scale not visible in the fluxgate data. Along the 1.2-kilometre section over the primary target, the NV-center data showed a gradient inflection approximately 35 metres east of the interpreted shear from the fluxgate data. A follow-up check against the closest drill hole log suggested the inflection aligns with a secondary sulphide stringer intersected at 94 metres depth in the drill core. This was not a pre-planned validation test, so we are cautious about drawing strong conclusions from a single correlation. But it was the kind of result that makes it worth continuing.
Over the third section with deeper target geometry (150 to 220 metres), the comparison was less clear. At that depth, the gradient anomaly amplitude falls below 0.5 nT/m over most of the section, which is near the noise floor of our current instrument in field conditions with wind-induced vibration noise. We saw signal in the data, but separating geological gradient from residual instrument noise at that level requires careful processing rather than a clean measurement. This is a genuine limitation of the current sensor specification at depth beyond 150 metres for low-contrast targets.
Logistics and operational realities
The instrument performed reliably across the full three-day field program. We had no sensor dropouts, no optical alignment failures on startup, and no temperature-related issues. The ambient temperature ranged from 14 degrees Celsius at 6am to 39 degrees Celsius at midday. Our thermal compensation ran throughout and the drift correction behaved as expected based on lab calibration.
Where the logistics were harder than expected was the per-station measurement time. Our current protocol for a ground traverse station requires approximately 45 seconds of stationary acquisition to reach the target SNR for gradient measurement. On a 10-metre spacing grid over 1.2 kilometres, that is roughly 120 stations per line, or approximately 90 minutes of acquisition per kilometre including instrument handling time. The exploration team expressed that this pace is workable for a targeted follow-up traverse but not for broad reconnaissance over tens of kilometres of line. Conventional fluxgate gradiometers in continuous tow mode cover ground an order of magnitude faster.
We are working on a moving-platform acquisition mode that uses higher photon flux and shorter averaging windows to reduce per-station time to under 15 seconds, with an acceptable penalty in sensitivity. Whether the sensitivity trade-off is acceptable depends on target depth and contrast, and we need more field data to characterise it properly.
Power and field handling
The sensor head and electronics draw approximately 18 W in the field configuration, powered from a 100 Wh lithium battery pack. Battery life over a full survey day of intermittent acquisition is approximately 5 hours before the first recharge cycle, which requires swapping battery packs once mid-morning and once mid-afternoon for a full 8-hour field day. In a Western Australian summer heat environment, the battery packs ran warm and we lost approximately 12 percent of capacity relative to the 25-degree rated specification. We have since added battery thermal management to the instrument housing to address this.
The instrument enclosure held up well to red dust ingress, which was a concern given the fine particulate environment. We use positive-pressure filtered air around the optical components and the seal integrity was maintained across the program.
What the pilot changed in our development priorities
Before this deployment, instrument development was primarily focused on pushing sensitivity. After the pilot, we added acquisition speed to the priority list at roughly equal weight. The geological result was encouraging enough to validate that the sensitivity improvement over fluxgate is real in the field, not just in the lab. But the operational pace limitation is a more urgent barrier to adoption in the exploration workflow than sensor noise floor at this stage.
We also came away with a clearer view of the target market within mining. Broad first-pass reconnaissance over hundreds of line-kilometres of unexplored tenure is not where our instrument fits today. Detailed follow-up over 10 to 20 line-kilometre areas with known indicators, at 10-metre spacing to resolve drill-target geometry, is where the sensitivity advantage is decisive and the pace limitation is acceptable. That is a smaller but very real segment of the exploration workflow, and it is where we will focus the next phase of evaluation.
There are no guarantees the next pilot will produce the same correlation quality. Different mineralisation styles, different lithology contrasts, and different depth distributions will all affect what the instrument sees. The honest version of our current status is that we have one very promising result and a list of engineering improvements to make before the next deployment.
We are accepting evaluation partnerships with exploration companies for targeted follow-up surveys. Contact us to discuss your tenement and target geometry.
Request Evaluation Kit